AI-Driven Obstacle Detection & Pathfinding for the Visually Impaired Formerly code-named IvoryCane
Navi-Netra fuses an ultrasonic sensor array with real-time CNN/YOLO object detection and A* pathfinding to give visually impaired users proactive, hands-free navigation in both indoor and outdoor environments.
Engineered by Arnav Sharma · Mentor: Sushil Kumar Pandey
Hardware
Device Architecture
Extendable cane form factor with custom-angled smartphone mount (8–9 cm above grip) and protective sensor chassis. Two compute generations were developed.
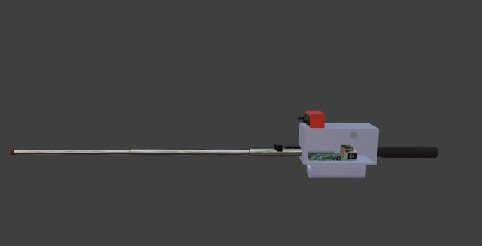
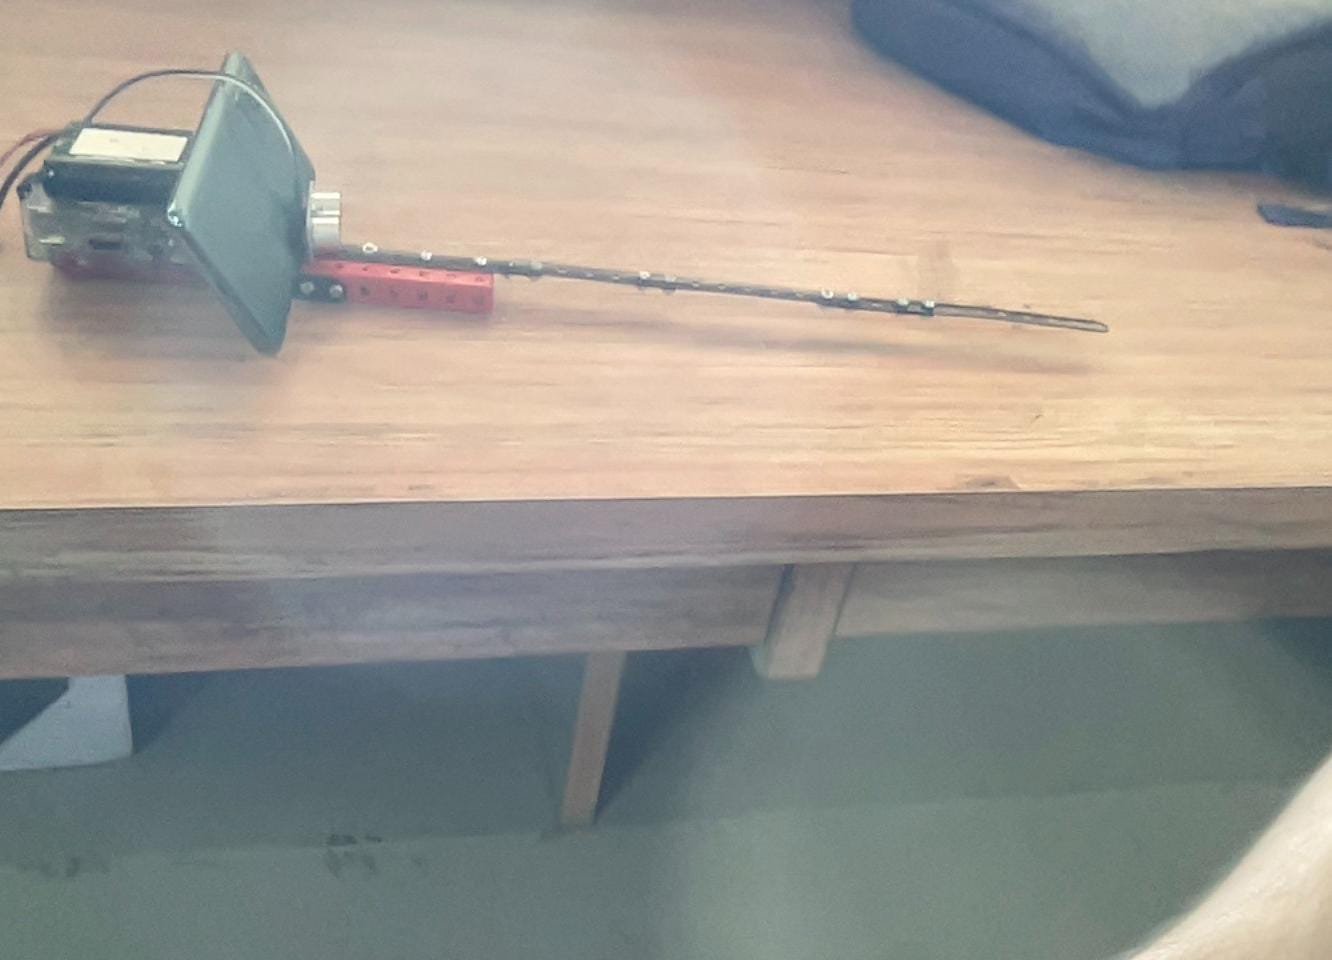
Ultrasonic Array
- Multiple HC-SR04 sensors
- Raw range: 2 cm – 400 cm
- ±3 mm sensor rating
- Effective hazard envelope: 0.5 m – 4.0 m
- ±3 cm precision at 1 m
Compute Evolution
- Gen 1: Raspberry Pi primary unit (CAD phase)
- Gen 2: Smartphone edge compute via wired data/power bridge
- Onboard USB-C power bank
- 8-hour continuous runtime
Audio & Form Factor
- Bluetooth low-latency audio relay
- Extendable cane w/ grip mount
- Protective sensor chassis at tip
- Bottom shield for ground-reflection filtering
Empirical Data
Benchmark Results
Human trials with N=10 visually impaired participants. All metrics measured under controlled and real-world field conditions.
| Metric | Value | Notes |
|---|---|---|
| Indoor classification accuracy | 92% | Walls, doors, chairs, steps |
| Outdoor classification accuracy | 85% | Including low-hanging branches, uneven terrain |
| Preferred over white cane (unfamiliar env.) | 80% | 8 of 10 participants |
| Higher navigation confidence | 85% | Self-reported improvement |
| Willing to adopt as primary aid | 78% | Post-trial survey |
| Comfort & weight score | 8.4 / 10 | Up to 2 hours continuous use |
| Overall satisfaction | 8 / 10 | Including audio clarity |
| Proactive alert vs. white cane contact | 2.5 m vs <1 m | Average hazard detection distance |
Software
AI & Sensor-Fusion Pipeline
Real-time object detection and dynamic pathfinding fusing ultrasonic distance telemetry with visual bounding boxes.
Research
Technical Whitepaper
Full 20-page research paper covering motivation, literature review, system design, methodology, results, and future scope.